 FIG. 00 — P. INGLE
Embodied AI and LLM safety researcher
I’m Pratik Ingle, a PhD candidate in Computer Science at the IT University of Copenhagen, working in the REAL Lab with Kasper Støy and Andrés Faíña on learning and control for grasp-free manipulation. My research sits at the intersection of tactile sensing and robot learning. In 2026, I was a visiting researcher at UCL’s CRISP Lab with Lorenzo Jamone, working on tactile perception for robot hands. Before my PhD, I completed a BS-MS in Electrical Engineering and Computer Science at IISER Bhopal and worked on multi-robot systems at NJIT’s Swarm Lab.
I’m interested in world models, in particular JEPA-style models that learn by predicting in latent space, and more recently in vision-language-action (VLA) models, LLM inference, safety, and evaluation.
Visual abstract
My research in four live demos. Pick one and try it.Try: · · · or click a block
Click to set a goal. The robot imagines 24 futures (dotted), coloured by score best → worst (grey: wall ahead), and follows the solid one towards the ring.
Try: · · · · or click a ball, then where it should go
No gripper: each ball follows a planned path (dashed) that keeps it clear of the others, and the actuators tilt the fabric to roll it along.
Turn defences on and the eval re-runs. Click a tile to see what the agent did.
Latest
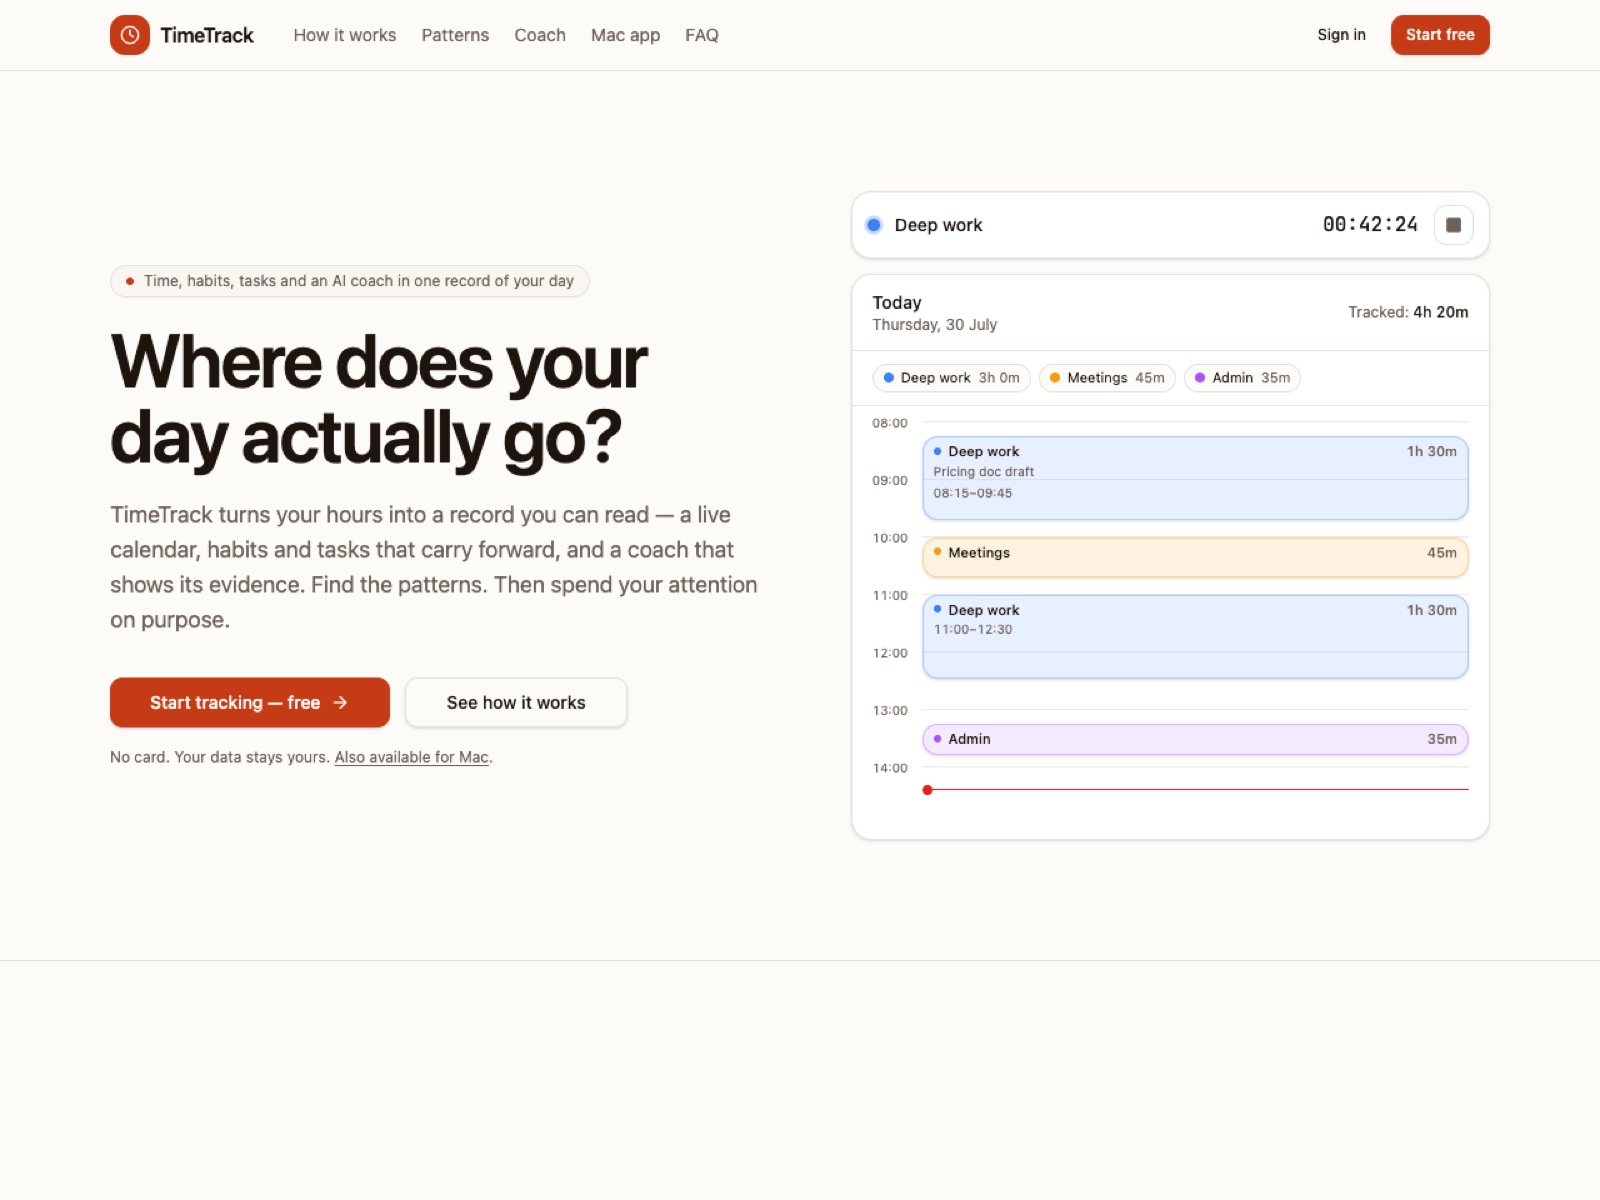
What I’m working on right now.- Time WeaverA time-tracking app with a built-in AI assistant and an MCP connector for Claude. Give it a try and tell me what you think.
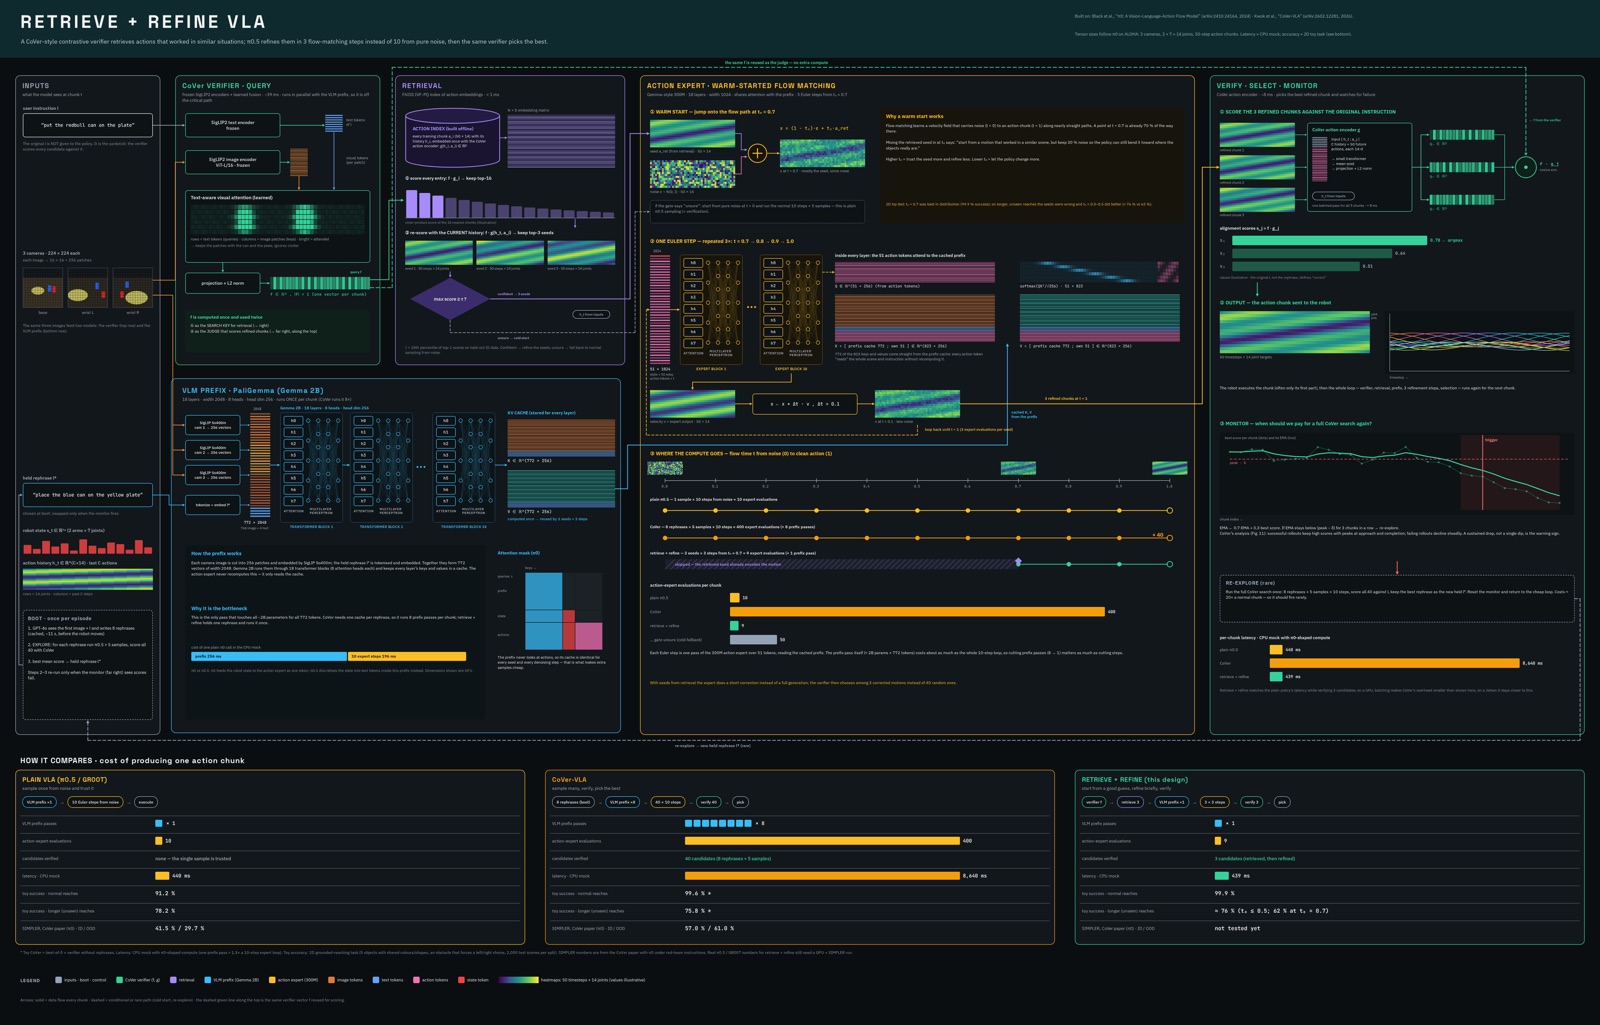
- Retrieve + Refine VLAVerified VLA actions for about the cost of one plain call. Now testing on LIBERO with π0.5.
- Thermodynamic solvers for robot state estimationCan a thermodynamic chip replace the digital solver in a robot’s control loop? Warm-started iterative refinement cut device time about 330× while matching an exact solver.
- Universal Coding LanguageWhere programming goes when AI agents write most of the code.