Papers and preprints.
Published work, manuscripts and papers under review.
- Manuscript · IEEE RA-L
Joint-Embedding Predictive Pretraining for Tactile Shape Recognition During Manipulation on a Simulated Membrane Surface
Self-supervised tactile learning 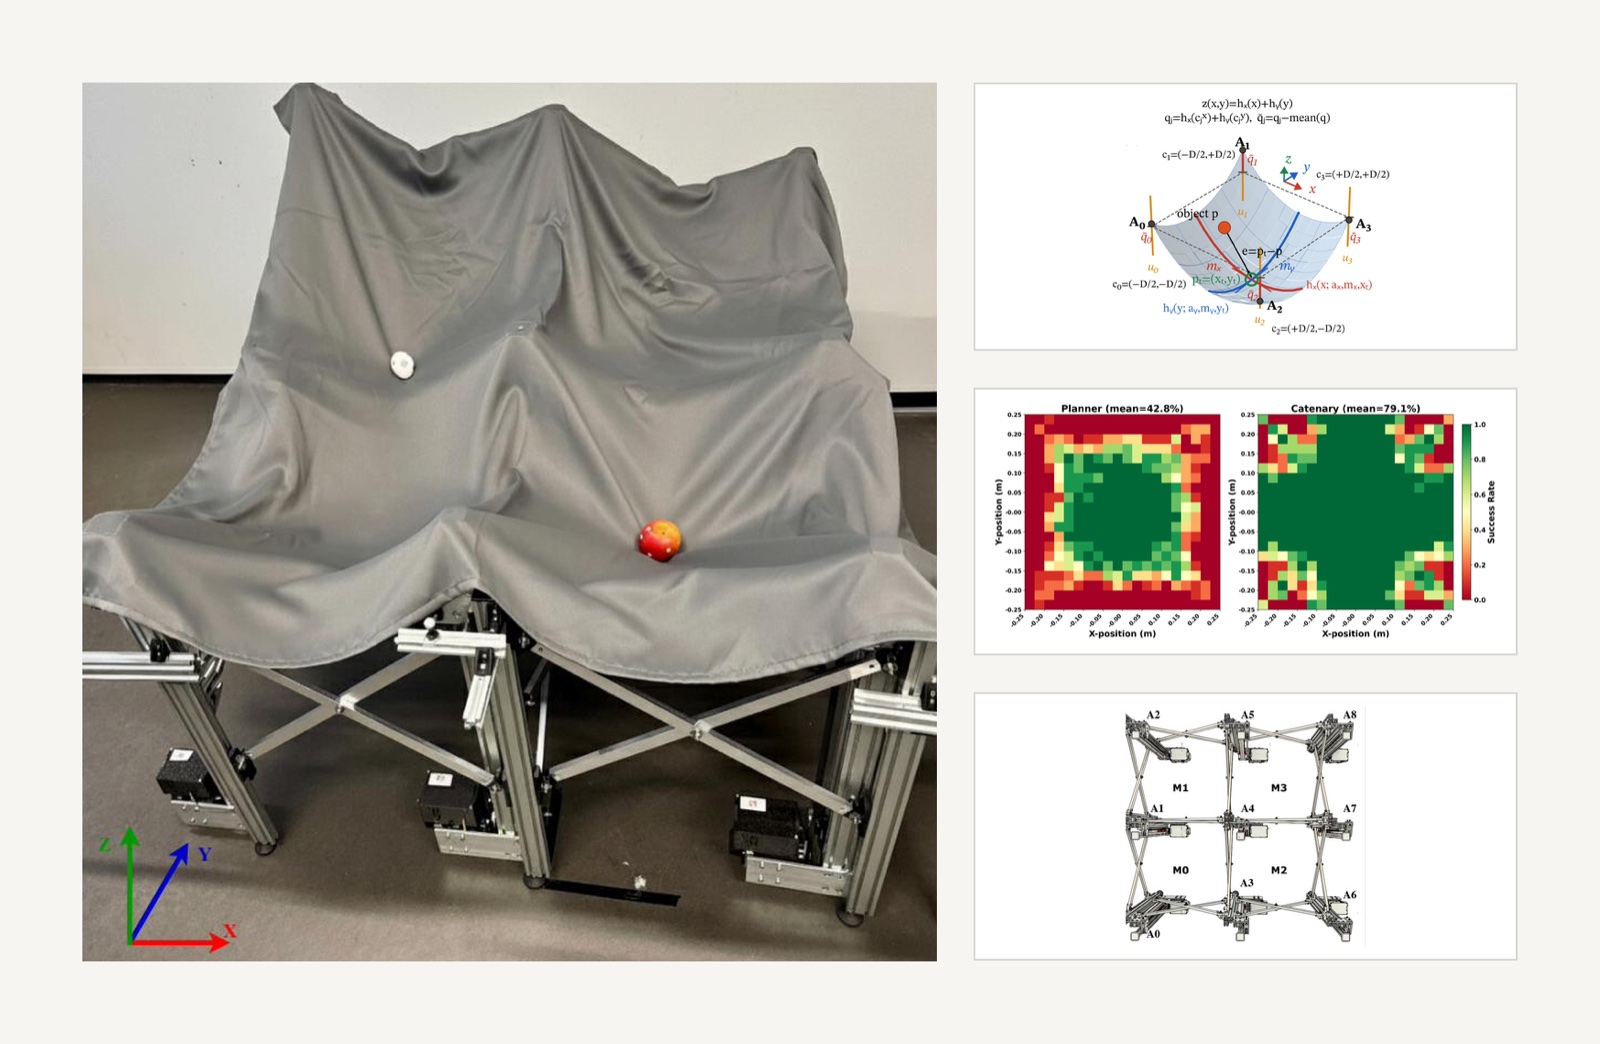 IEEE ICRA 2027 · Under review
Suspended-Fabric Robotic Manipulation Surfaces: Modelling, Design Space, and Multimodular Extension
IEEE International Conference on Robotics and Automation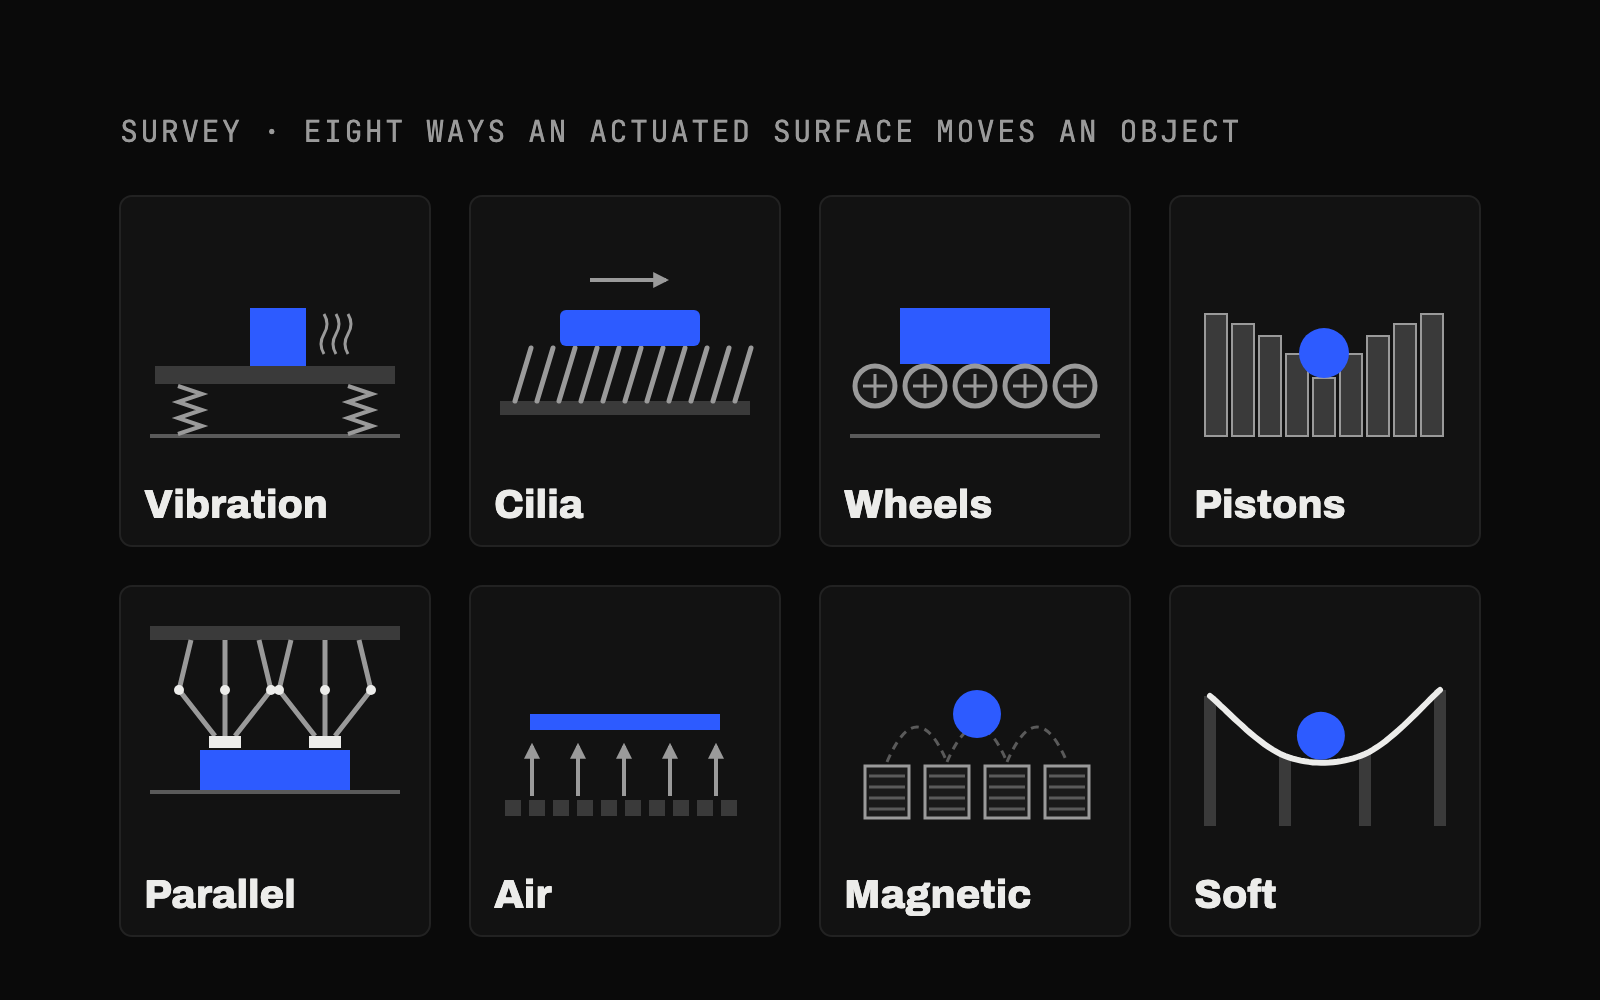 IJRR · Under review
Survey of Robotic Manipulation Surfaces: Challenges and Opportunities
International Journal of Robotics Research- SAB 2026
Scalable, Distributed Control of a Manipulation Surface with Emergent Properties
18th International Conference on the Simulation of Adaptive Behavior, GermanyDOI ↗Code ↗BibTeX
@inproceedings{10.1007/978-3-032-39953-3_1, title = {Scalable, Distributed Control of a Manipulation Surface with Emergent Properties}, booktitle = {From Animals to Animats 18}, author = {Stoy, Kasper and Ingle, Pratik and Lambertsen, Jørn and Faíña, Andrés}, editor = {Brock, Oliver and Krichmar, Jeffrey and Mengers, Vito}, date = {2027}, pages = {3--14}, publisher = {Springer Nature Switzerland}, location = {Cham}, abstract = {Distributed manipulation surfaces promise scalable, parallel handling of many objects, but how to control them distributedly remains a challenging question. We address this on the MANTA-RAY distributed manipulation system where a fabric is suspended over a grid of pistons. We report on three contributions. First, a computationally efficient catenary-based simulation whose computational cost is independent of the surface size and in the worst case quadratic in the number of objects allowing for simulation at scale. Second, a strictly local control methodology based on a static control table and local sensing. Despite this locality, global behaviors work as designed and, further, we see emergent clustering behavior for which we did not explicitly design. Third, with a priority-based extension, the same controller produces letter formation (“SAB”) on a 7×15 grid-cell, 128-piston system with a 100/100 success rate. The results are a contribution to efficient simulation and large-scale control in the growing field of distributed manipulation surfaces.}, isbn = {978-3-032-39953-3} } - arXiv:2601.21884
Scalable Surface-Based Manipulation Through Modularity and Inter-Module Object Transfer
With J. Lambertsen, K. Støy and A. FaíñaarXiv ↗BibTeX
@misc{ingle2026scalablesurfacebasedmanipulationmodularity, title={Scalable Surface-Based Manipulation Through Modularity and Inter-Module Object Transfer}, author={Pratik Ingle and Jørn Lambertsen and Kasper Støy and Andres Faina}, year={2026}, eprint={2601.21884}, archivePrefix={arXiv}, primaryClass={cs.RO}, url={https://arxiv.org/abs/2601.21884}, } - IEEE CASE 2025
Heterogeneous Object Manipulation on Nonlinear Soft Surface Through Linear Controller
IEEE Conference on Automation Science and EngineeringDOI ↗Video ↗Project page ↗BibTeX
@INPROCEEDINGS{11163787, author={Ingle, Pratik and Støy, Kasper and Faiña, Andres}, booktitle={2025 IEEE 21st International Conference on Automation Science and Engineering (CASE)}, title={Heterogeneous object manipulation on nonlinear soft surface through linear controller}, year={2025}, volume={}, number={}, pages={1780-1787}, keywords={Training;Actuators;Shape;Soft robotics;Hardware;Fabrics;Robustness;Complexity theory;Trajectory;Surface texture;Manipulation;Soft Robot;Robotic Manipulation Surface}, doi={10.1109/CASE58245.2025.11163787}} - IEEE RoboSoft 2025 · Highlight talk
Soft Manipulation Surface With Reduced Actuator Density for Heterogeneous Object Manipulation
IEEE International Conference on Soft RoboticsDOI ↗Video ↗Project page ↗BibTeX
@INPROCEEDINGS{11020841, author={Ingle, Pratik and Støy, Kasper and Faiña, Andres}, booktitle={2025 IEEE 8th International Conference on Soft Robotics (RoboSoft)}, title={Soft Manipulation Surface With Reduced Actuator Density For Heterogeneous Object Manipulation}, year={2025}, volume={}, number={}, pages={1-8}, keywords={Meters;Hands;Actuators;Shape;Robot kinematics;Reinforcement learning;Soft robotics;Hardware;Reliability;Grippers;Manipulation;Soft Robot;Surface Manipulation;Robotic Manipulation Surface}, doi={10.1109/RoboSoft63089.2025.11020841}} - ANTS 2024
Moving Depot (MOD): An Efficient Depot Motion Strategy for Multi-Robot Foraging
14th International Conference on Swarm Intelligence, Germany