Human-to-robot hand retargeting
A pipeline that turns egocentric human hand poses into LEAP-hand actions for in-hand multi-object manipulation.
- Type
- Research
- Tracks
- Robotics · ML
- Context
- UCL CRISP Lab · 2026
- Links
- Code ↗
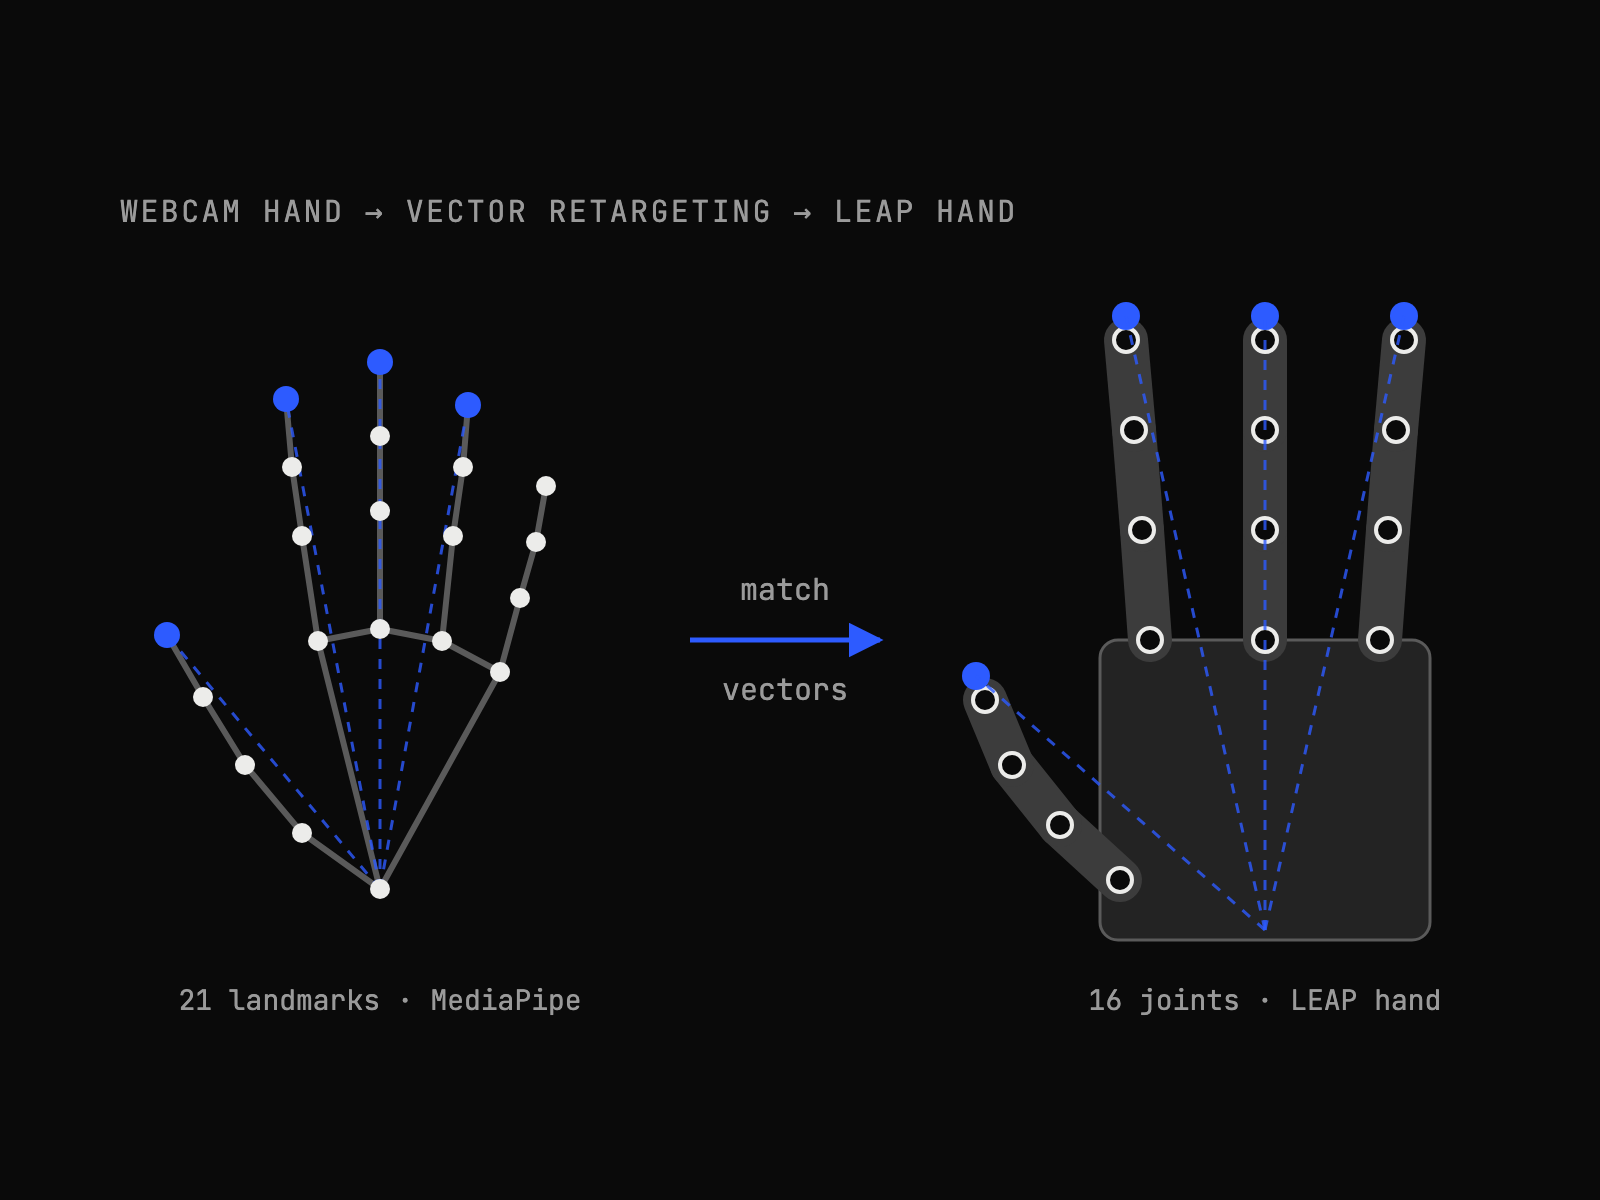 FIG. 02
Overview
[Expand on the summary above: the question, why it matters and where it fits in the field.]
Approach
[Setup, method and the key design decisions. Add figures with  after placing the file in public/media/.]
Results
[Headline numbers, plots or rollout clips, and what they show.]